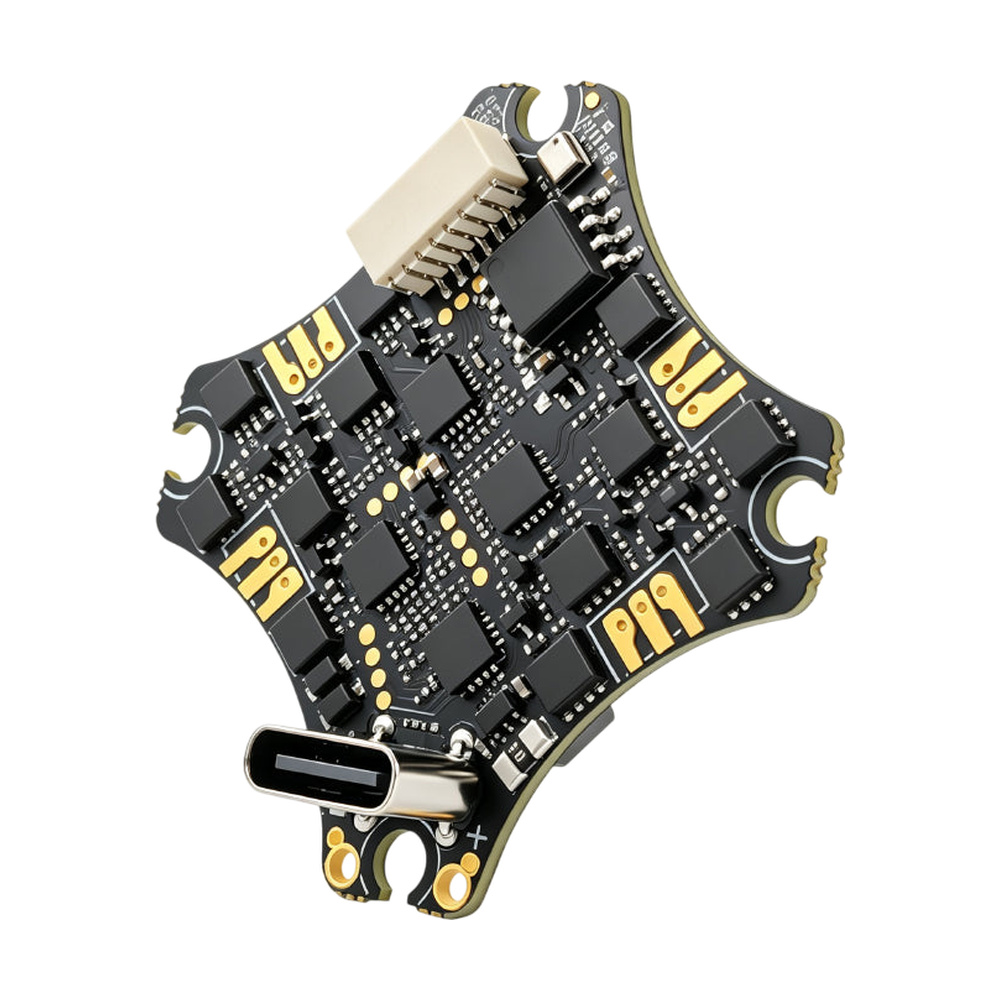
DarwinFPV 4.9g Ultra-Light 15A AIO is an AIO board combining a flight controller, 15A ESCs and an ELRS receiver. The board is suitable for 65, 75 and 85 mm whoops and lightweight 1.6-3" toothpicks powered by a 1-3S LiPo battery. It can be used with both analog and digital video transmission – the board features an OSD chip for analog video as well as a connector for digital video transmitters such as DJI O4 or Walksnail. The flight controller runs Betaflight firmware.
The flight controller is based on an AT32F435 processor clocked at 288 MHz combined with an ICM42688 gyroscope. Compared to the F411 used on older boards of this size, the processor offers significantly higher computing performance, handling high PID loop frequencies and more demanding filtering. The gyroscope has its own LDO power regulator that filters interference from other circuits. The board includes a barometer for altitude measurement and 16 MB of blackbox memory. There are 5 UARTs and I2C pads (SDA, SCL) for connecting a GPS module with compass. The 5V/3.5A BEC maintains stable voltage even when battery voltage drops to 2.8 V, preventing a digital video transmitter from restarting with a low 1S cell. The board also has pads for an LED strip and buzzer.
The integrated ELRS receiver at 2.4 GHz is connected via UART, and the antenna is included. To use an external receiver (ELRS, TBS Crossfire or SBUS), the integrated receiver power can be disconnected by cutting the solder bridge, and the external receiver can be connected to UART2.
A digital video transmitter connects via a 6-pin connector (VCC, GND, TX, RX, GND, SBUS) on the underside of the board. By default, the connector is powered directly from the battery. For 1S operation, switch it to 5V from the BEC by moving the 0Ω resistor or bridging the solder pads. An analog video transmitter and camera are soldered to the VTX, CAM and 5V pads, and the video transmitter is controlled via UART7 (SmartAudio).
The ESCs use Bluejay firmware and support the DShot300/600 protocol. They handle continuous current of 15A per channel, making them suitable for motors from size 0702 to 1303. The board includes a current sensor. Motors can be connected in three ways – soldered to pads or through the included vertical or horizontal JST1.25 connectors, which can be installed on either the top or bottom side of the board. The solder pads are enlarged and reinforced for easier soldering.
The mounting hole spacing is 25.5x25.5 mm, board dimensions are 33x33 mm, and weight is 4.9 g. The battery connects via the included XT30 connector with 20 AWG wire. We recommend soldering the included 220 uF/16 V capacitor to the power pads to suppress voltage spikes. The USB-C connector is located on the rear edge of the board, allowing access without disassembling the drone.
Important: To connect to Betaflight Configurator in Windows, the virtual COM port driver from the Artery processor manufacturer must be installed.
Key Features
- Input voltage: 1-3S LiPo
- MCU: AT32F435 (288 MHz)
- Gyro: ICM42688
- Barometer: Yes
- Blackbox: 16 MB
- OSD: Yes (AT7456E)
- Number of UARTs: 5
- I2C: Yes
- BEC: 5V/3.5A
- Video transmitter connector: 6-pin for digital VTX (BAT/5V power), solder pads for analog
- RC receiver: Integrated ELRS 2.4 GHz (UART)
- Antenna connector: IPEX1
- Firmware target: DARWINF435 (Betaflight)
- ESC firmware: Bluejay (S-H-50)
- Continuous current: 15A
- Input protocol: DShot300/600
- Current sensor: Yes
- Motor connector: JST1.25 (vertical and horizontal) or solder pads
- Power connector: XT30
- USB connector: USB-C on board
- Mounting holes: 25.5x25.5 mm M2
- Size: 33x33x9.5 mm
- Weight: 4.9 g
Package Includes
- 1x AIO board
- 1x XT30 connector with cable (20 AWG, 70 mm)
- 1x ELRS antenna
- 1x Set of vertical motor connectors (JST1.25)
- 1x Set of horizontal motor connectors (JST1.25)
- 1x Set of soft mounts (M2x6.6 mm)
- 1x Set of M2x8 screws and M2 nylon nuts
- 1x 220 uF/16 V capacitor
- 1x Insulating pad
- 1x Set of stickers